On October 29, MBZUAI published a new explanation of Imagination at Inference: synthesising a robot's wrist-camera view. The research is older: its arXiv record dates to September 19, 2025.
What the study actually establishes
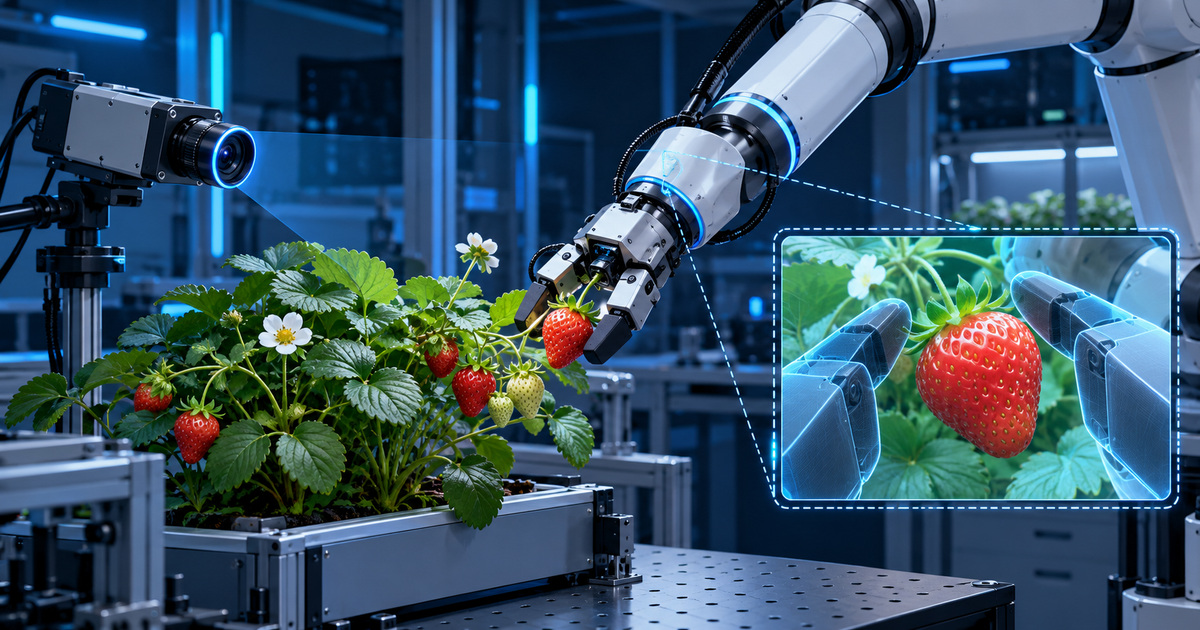
The method uses ZeroNVS with LoRA, an external image and the robot's pose. In a Unitree Z1 experiment with a plastic strawberry, successes were 3/10 with an external camera alone, 6/10 with a generated view and 8/10 with a real wrist camera.
Simulations rerun only initial failures, leaving possible new errors in other trials unmeasured. The university specifies that a real camera is still needed for training data and synthesis is not real-time. The small physical sample does not demonstrate field reliability.
A predicted view and a measurement answer different questions
Our editorial assessment is that the useful question concerns uncertainty. A generated image may supply a helpful geometric cue, but a convincing appearance does not itself establish the actual location of a hidden object. An evaluation should explain when the robot continues and when it should seek another observation.
An illustrative future test would use the same set of positions for every configuration, including the initially successful cases. We would separately record failed grasps, decision time and cases in which the system chooses to stop. This is a proposed editorial evaluation, rather than an experiment we performed or an outcome claimed by the researchers.
The task boundary also matters. Manipulating one known artificial strawberry and handling an unfamiliar object among changing obstructions require different evidence. In our view, the method's usefulness should be assessed by behaviour across such differences, rather than only by the visual quality of a predicted frame.
The new explanation makes the research more accessible and illustrates a specific way to combine generative models and control. The verified evidence nevertheless supports a bounded laboratory result. SIExpo has not reproduced the experiments and does not claim that an autonomous robot for harvesting a real crop has been demonstrated.
*AI illustration: a laboratory concept with an artificial fruit and predicted view, not a photograph of the experiment.*
*Editorial verification: 30.10.2026, 09:13:25 +0200 (Europe/Sofia).*