AGIBOT's public LIFE repository records a November 10, 2026 RoboBeats update: frame-by-frame operation with cache reuse, custom conditions and a live camera or video demo. That is the specific new development. Weights and code were announced earlier, on November 3, and the research paper dates to October 30. Later media coverage does not move those dates or constitute a new release of the entire project.
Observation that selects
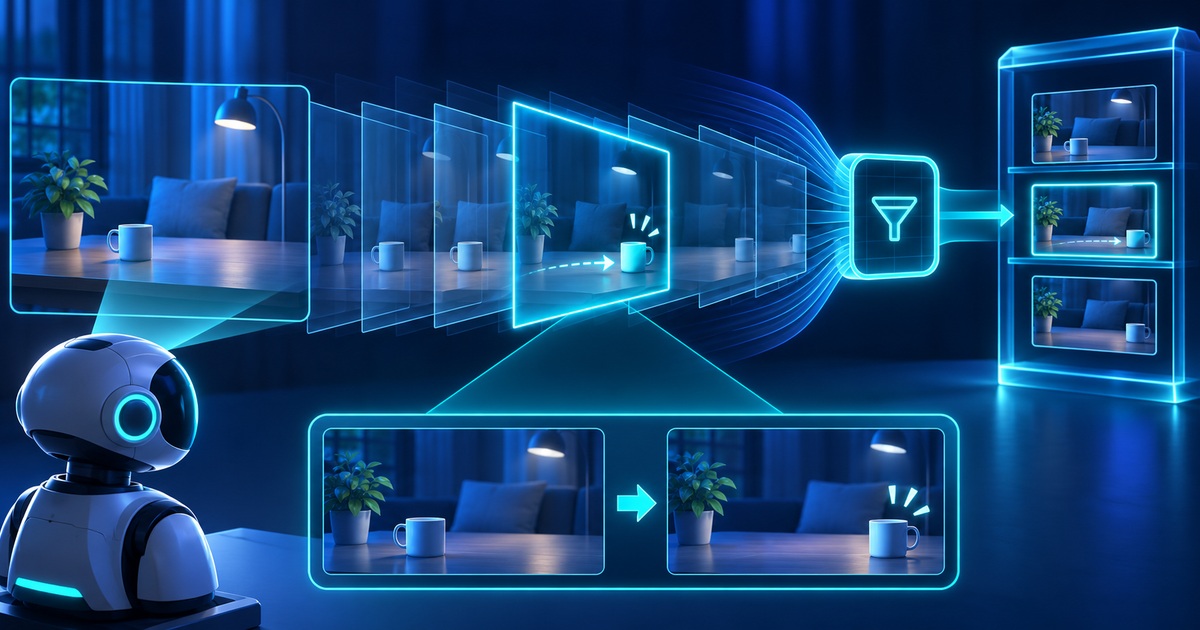
RoboBeats is a small vision-language gate that scores a one-frame-per-second stream. Its documentation distinguishes event discovery from tracking user-defined conditions. In the demo, frames go to the server the operator runs, and results appear as processing progresses. A local demo therefore requires knowing where that server is; it does not automatically mean that all computation happens inside the browser.
In the wider research architecture, selected observations enter Plastic Memory, which retains images and structured records. A separate EDM mechanism is intended to turn solutions found during problem solving into reusable skills. The authors present a limited case study replaying 24 hours of robot video. This is research evidence under particular conditions, rather than a demonstration that any robot continuously learns and safely performs arbitrary new tasks.
What the benchmark checks
SSS-Bench evaluates questions about sparse events in long video streams under a causal protocol: an answer must use only observations available so far. Its documentation describes 618 questions over 171 source videos, up to 30 minutes long. That measures retention and use of observed information. It is not a direct test of motor safety or object-manipulation ability.
Code is under Apache 2.0, while SSS-Bench materials and rubrics use CC BY-NC 4.0. Source videos retain their own licenses and are not redistributed with the benchmark. The project's different components should therefore not be presented as one unrestricted commercial package.
Why selection matters
Our editorial analysis is that a robot's memory has two separate problems: deciding what to retain and determining whether retained evidence is sufficient for a later answer. A smaller archive may be useful if it preserves important changes. But an observation missed earlier is not recovered merely because the next language model is stronger. Selection quality therefore needs assessment against concrete future tasks, rather than just a count of recorded frames.
A hypothetical laboratory check might move a cup between two positions and later ask where it was before the move. A correct answer about its latest position does not establish that its history was retained. Conversely, a detailed archive does not establish that the system can retrieve the right moment. The example separates observation, recording and retrieval without presenting a test of ours or an AGIBOT result.
For practical evaluation, preserving the origin and time of evidence supporting an answer is useful. If the system did not observe an interval, that should remain unknown rather than being completed with a plausible narrative. The same discipline makes a demo easier to understand: it shows what works, under which input stream and with which limits.
SIExpo has not run RoboBeats or tested a robot. The update is useful as an accessible way to investigate selective observation. It does not certify a finished home assistant, autonomous skill development or independently verified superiority over every other approach.
Sources: AGIBOT - November10 live RoboBeats update, RoboBeats - streaming gate and condition tracking, SSS-Bench - evaluation and licensing, LIFE - original October30 research paper.
The cover is a conceptual AI illustration, not a documentary photograph.
Editorial verification: 2026-11-13T07:35:06.745176+00:00.