The Whole-Body Dexterity preprint, submitted on October 15, 2026, examines manipulation using contact with the arms and torso. A controller trained in simulation transfers to a Unitree G1 guided by a human operator. The authors report 45 successful trials out of 50 overall; the complete shelf-to-table task succeeds in 7 of 10 trials. These are research results, not an independent SIExpo evaluation.
Contact is part of the task
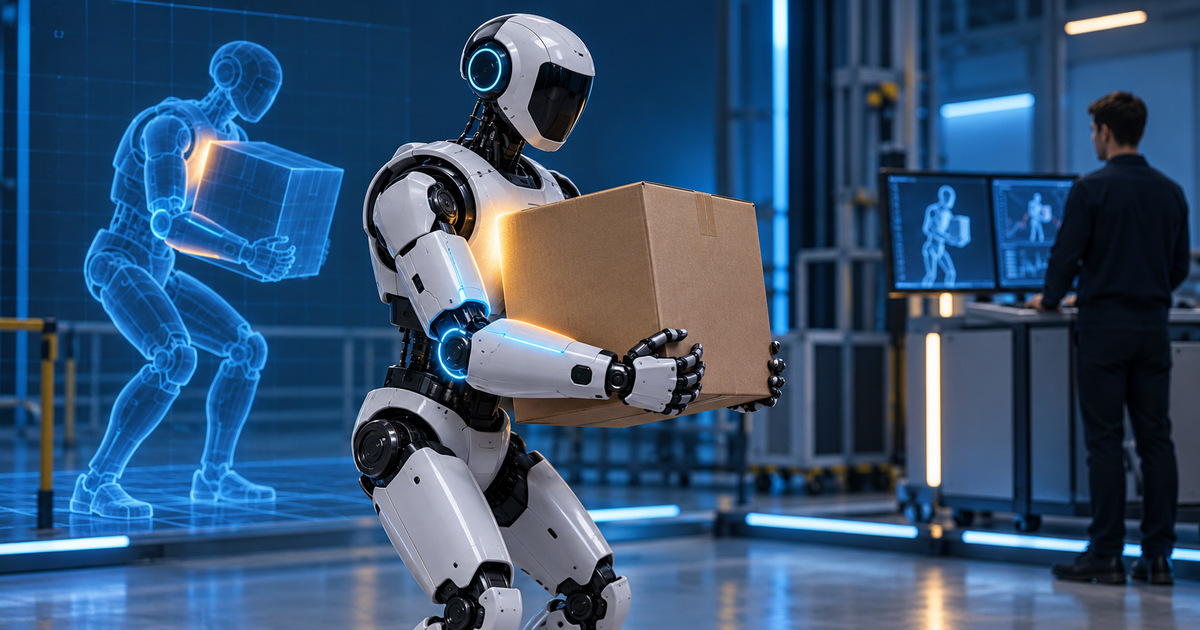
An intuitive example is a person bracing a box against the body to free one hand. Reaching a new arm position is not sufficient: the object must remain supported during the transition. This is our explanation of the engineering problem. It does not establish that the demonstrated robot can carry arbitrary loads or work safely beside people without additional testing.
A complete sequence also differs from a successful beginning. Picking up a box does not establish that it will be held, carried and placed correctly. Our conclusion is that intermediate and final success criteria should be considered separately. Otherwise, one short successful movement can produce a stronger impression than the evidence supports or obscure a failure occurring later in the workflow.
The platform and controller have separate scope
Unitree’s official product page distinguishes G1 from G1 EDU, with different capabilities and options. It lists 23 degrees of freedom for the basic variant and a 23–43 range for EDU. These are product specifications, not proof that every possible configuration can reproduce the research. We do not infer universal compatibility merely from the shared G1 name.
For an organization’s own assessment, we recommend recording the exact hardware and settings, selected objects and definition of success. Failed attempts should be retained as well. That makes it easier to distinguish a reproducible skill from a selected video clip and to see whether changing conditions affects the final outcome. This is an evaluation recommendation, rather than a test our newsroom has conducted.
Human steering is a material condition of the demonstrated work. We therefore do not describe the system as an independent warehouse-task planner. Such a claim would require separate evidence covering task selection, unexpected situations and safe termination. A useful assessment would make clear which decisions come from the operator and which behavior is contributed by the controller, rather than treating all observed movement as one autonomous capability.
The contribution here is narrower and concrete: improved management of contact during manipulation, measured in a defined research setting. It is interesting precisely because it addresses a specific physical difficulty. Keeping the experimental conditions visible allows readers to recognize that progress without assigning the robot untested general-purpose autonomy.
Editorial verification: 2026-10-19T16:25:17.197918+00:00 (UTC). Cover: conceptual AI illustration, not a documentary photograph.