On November 9, 2026, MIT presented FLEX, joint research with New York University on correcting robot behavior through language. The work is headed for CoRL; its preprint dates to October 20. The team includes Audrey Lee, Nathaniel Dennler, Ilia Sucholutsky and Andreea Bobu. This is a new university account of existing research, rather than a consumer-product launch.
From one object to a broader preference
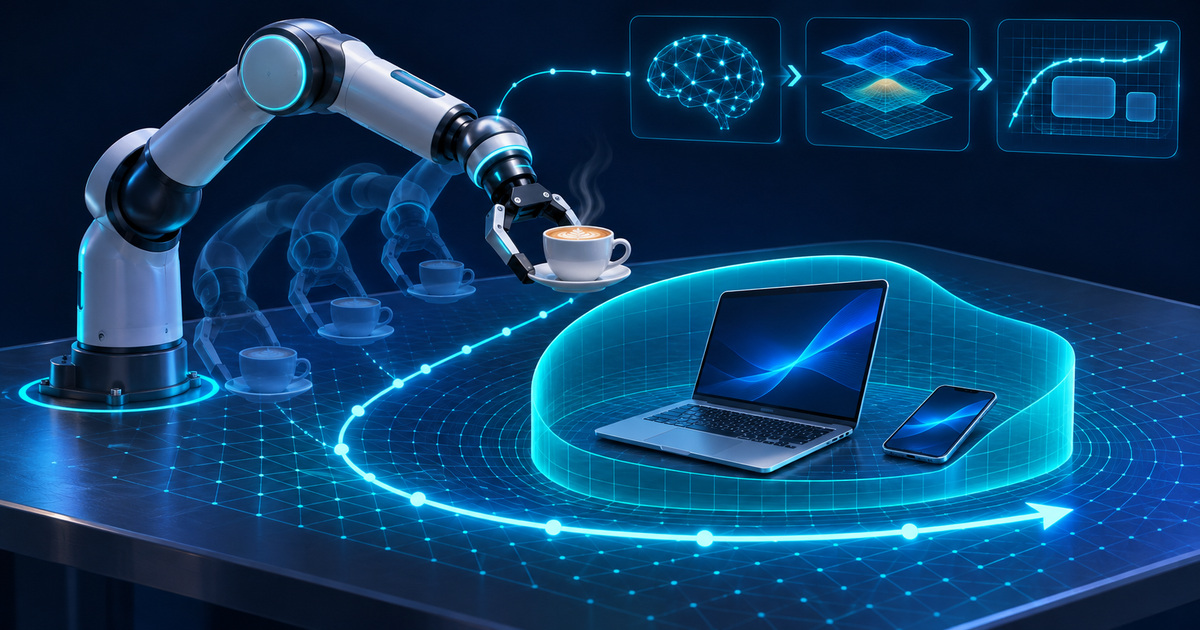
The approach edits the features considered when selecting a trajectory. Three operations add a missing feature, generalize an overly specific one and mask an irrelevant one. A warning about a laptop near a drink can, for example, become a preference to protect electronic devices. MIT describes coffee, candle and ball scenarios; the language model used is GPT-4o.
The project page makes an important distinction: language specifies which features matter, while demonstrations help learn their relative weights. Evaluation covers two-dimensional navigation and Franka manipulation. In the 12-person study, participants watched simulation for safety; real language corrections and demonstrations collected on a physical arm were used for offline learning. This does not establish autonomous operation in occupied homes.
The preprint compares the combined method with individual-operation approaches and an undecomposed language-model query. The authors report higher normalized reward and more compact representations. That metric concerns the defined tasks and preferences; it is not a universal safety-success percentage. SIExpo has not reproduced the experiments.
Editorial assessment: useful generalization has boundaries
The practical question is how a robot understands what matters when objects change. Memorizing a list of individual objects requires another correction after every rearrangement. Generalizing too broadly can rule out an entirely acceptable path. A useful demonstration therefore needs both successful preference transfer and cases in which generalization is inappropriate.
A future evaluation could use the same table with fragile and robust objects in different arrangements. Allowed trajectories and a clear stopping condition would be defined beforehand. After a language correction, the evaluation would measure whether the change protects the intended objects without blocking the task. This is our proposed criterion, not an additional FLEX result.
The point at which a masked feature becomes relevant again also matters. An object disappearing from the visible scene does not necessarily mean its risk has disappeared. A real application would need to combine language-based adaptation with dependable perception, movement constraints and a way for a person to interrupt. A persuasive verbal response does not establish physical safety.
FLEX is a concrete attempt to connect human intent with mathematical planning. Its public materials make the method and evaluation setup inspectable, while the simulation boundary remains an essential part of interpreting the result.
Editorial verification: 2026-11-09T07:12:30.497786+00:00.