On November 11, 2026, Runway released Praxis-1 weights and code under Apache 2.0. This is the public release following September’s introduction. Developers now have concrete artifacts to work with, while checkpoint selection, robot adaptation and evaluation remain separate tasks.
Video and action in one model
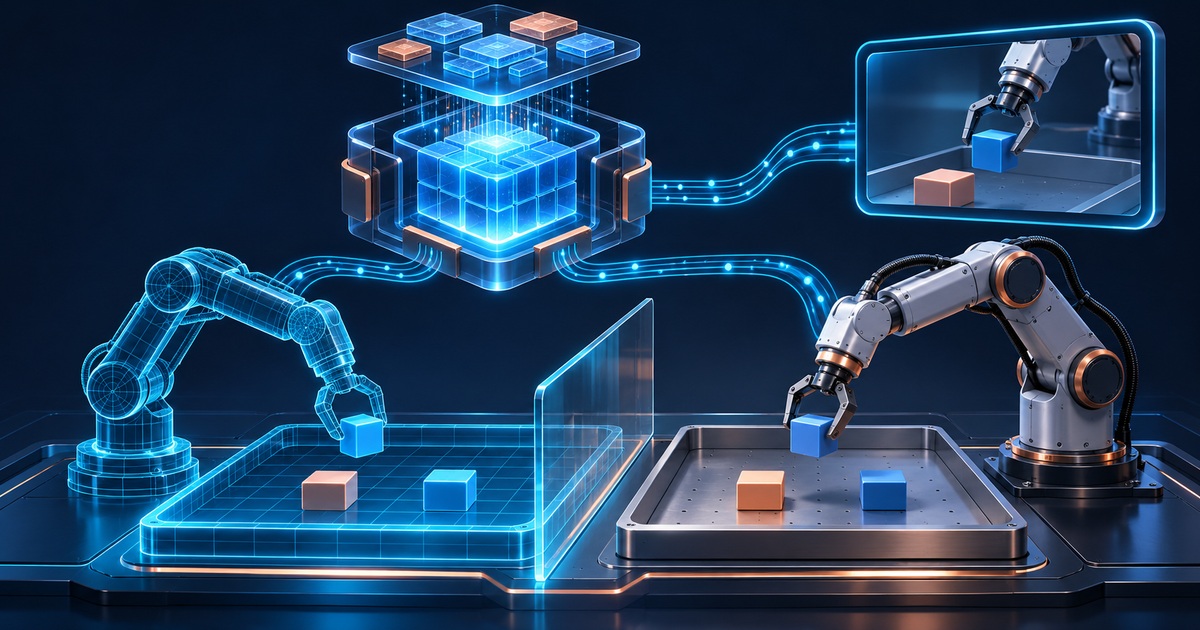
The technical presentation describes a mixture-of-experts diffusion architecture predicting video and robot actions jointly. Motion is modeled together with the expected change in a scene. The study discusses simulation and real-robot experiments separately; good image prediction is not treated here as automatic proof of safe movement.
Configuration and protocol matter when reading results. Changes to mechanics, cameras, control frequency or state representation can require further adaptation. That is the engineering context of a robot model, rather than a conclusion that can be drawn simply from parameter count.
Base weights are not a ready policy for every robot
The praxis-1-base card explicitly says that the base checkpoint lacks embodiment-specific action heads. It is a starting point for fine-tuning a new rig, not a policy ready to execute as-is. The card distinguishes DROID and YAM variants and identifies frozen external dependencies with their own licenses.
This matters to the meaning of open weights. A user receives an artifact and permissions under its license, but still needs to inspect dependencies and choose the appropriate variant. A public repository does not establish universal hardware compatibility.
The checked code’s Quick start describes Python 3.12, a CUDA environment and a GPU with at least 80 GB of memory for its specified initial simulation route. The repository includes inference, serving and fine-tuning instructions. Those are requirements of a particular example, not proof that every other variant necessarily uses the same amount of memory. SIExpo has not installed or executed the code.
What RoboLab-120 establishes
NVIDIA’s official table lists Praxis-1 with 555 successful episodes out of 1,200, or 46.2%. Four entries rank higher in the overall table. A description such as first world action model, or a comparison with particular open policies, must therefore retain its category boundary; it does not mean first among all approaches.
The table also distinguishes policy types, training-data information and other parameters. Even an aggregate percentage does not independently describe action time or training conditions. A leaderboard position is useful comparative evidence, not a guarantee for a new real-world workflow.
What public release enables
Our editorial assessment is that this stage’s value lies in inspectability. An external team can identify a precise artifact, trace its dependencies and begin a bounded evaluation. That is more concrete than watching selected demonstrations, but it does not erase the difference between an opportunity to reproduce a result and a result actually reproduced.
A reasonable evaluation would start with simulation and fixed tasks. Only then does it make sense to assess the corresponding physical robot under separate movement and observation constraints. The record should retain failures as well, so that a convenient demonstration does not become the only acceptance criterion.
Praxis-1 is significant because weights, code and distinguishable adaptation variants are available. The useful interpretation combines that openness with specific questions: which checkpoint, which robot, which protocol and which result has actually been checked? Neither the license nor a single percentage answers those questions for the developer. Reported performance remains tied to its evaluation setting, and real-system reliability needs its own evidence.
Sources: Runway — Praxis-1 public release, Runway — Praxis-1 technical study, Runway — Praxis-1 released code, Runway — Praxis-1 base model card, NVIDIA — RoboLab-120 official leaderboard.
The cover is a conceptual AI illustration, not a documentary photograph.
Editorial verification: 2026-11-12T07:52:16.361310+00:00.